All Pioneers (100)
Profile 95 of 100
1967– advanced

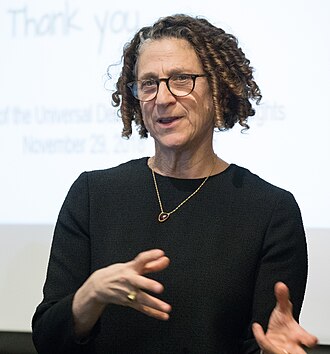
Lydia Kavraki

Noah Harding Professor at Rice & Inventor of Probabilistic Roadmaps
Lydia Kavraki

Biographical Overview

Noah Harding Professor of Computer Science and Bioengineering at Rice University. In 1996, Kavraki co-invented the Probabilistic Roadmap Method (PRM), solving the fundamental high-dimensional motion planning problem for autonomous robots, surgical arms, and molecular drug discovery.

"By sampling high-dimensional space randomly rather than systematically, we turned an impossible mathematical puzzle into a solved engineering problem."

— Lydia Kavraki
Lifespan 1967–
Technical Depth advanced
Key Breakthrough Probabilistic Roadmap Method (PRM, 1996) & Open Motion Planning Library (OMPL)
Focus Areas
robotics motion planning computational biology
Topic Keywords
#robotics #motion-planning #prm #bioinformatics #algorithms
Source: Historical Biographical Archive / Wikimedia Commons
💡

Historical Context & Impact

In short

Before Kavraki published her PRM algorithm in 1996, calculating a safe path for an eight-jointed robotic arm around obstacles was considered computationally intractable, requiring hours of calculus. Kavraki showed that randomly sampling collision-free waypoints connected the dots in milliseconds, unlocking modern autonomous robotics.
Key Technical Breakthroughs & Inventions

01
Probabilistic Roadmap Method (PRM, 1996) Invented PRM, a randomized sampling algorithm that builds a topological roadmap of free configuration space, solving high-dimensional robot motion planning in milliseconds.
02
The Open Motion Planning Library (OMPL) Co-developed OMPL, the standard open-source library used by NASA, academic robotics labs, and the Robot Operating System (ROS) worldwide.
03
Computational Structural Biology & Drug Design Adapted geometric motion planning algorithms to simulate flexible protein-ligand docking, predicting how small drug molecules bind to viral targets.
04
Biomedical Robotics & Surgical Automation Engineered collision-free path planning algorithms for snake robots and steerable surgical needles used in minimally invasive operations.

Selected Honors & Industry Recognition

Original Publications, Papers & Archives

Connected Contemporaries

All 100 Pioneers →